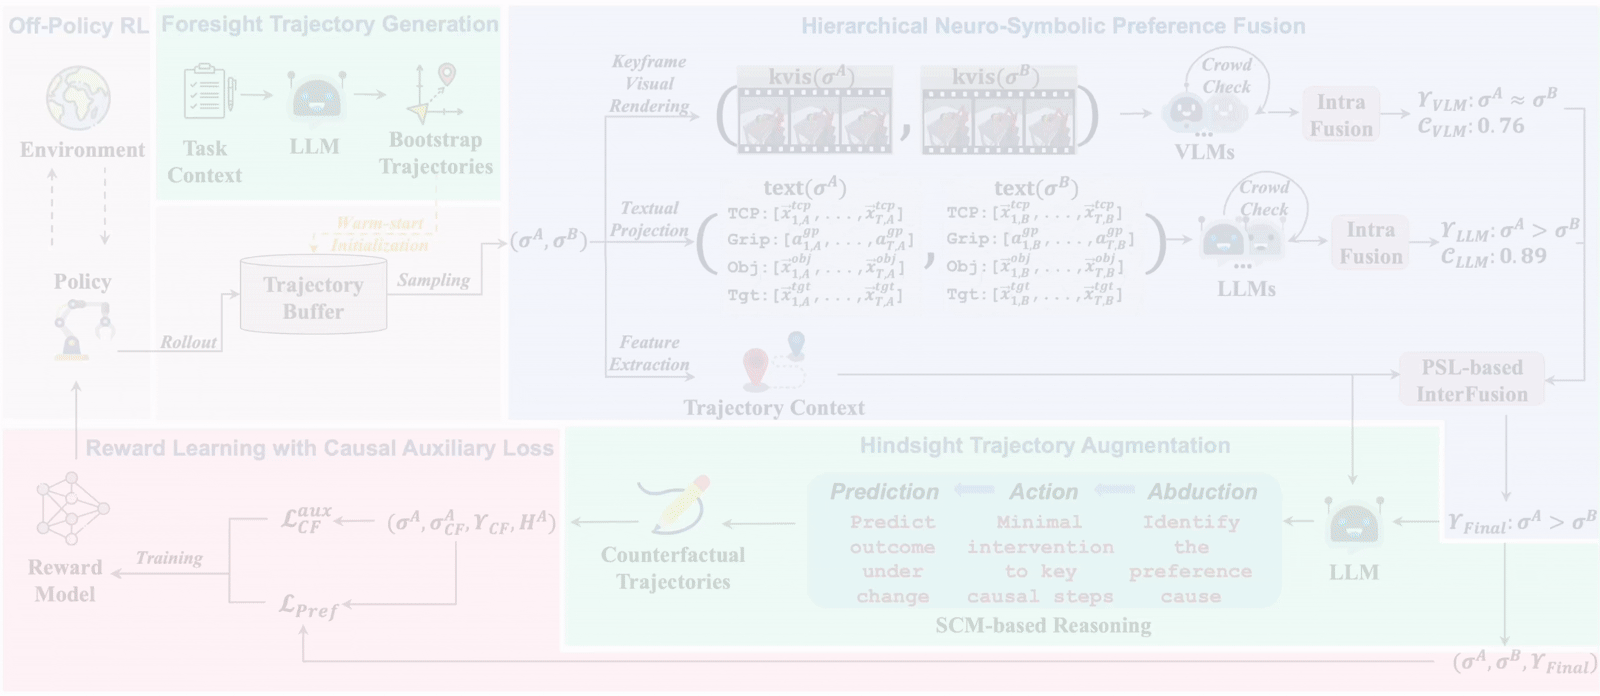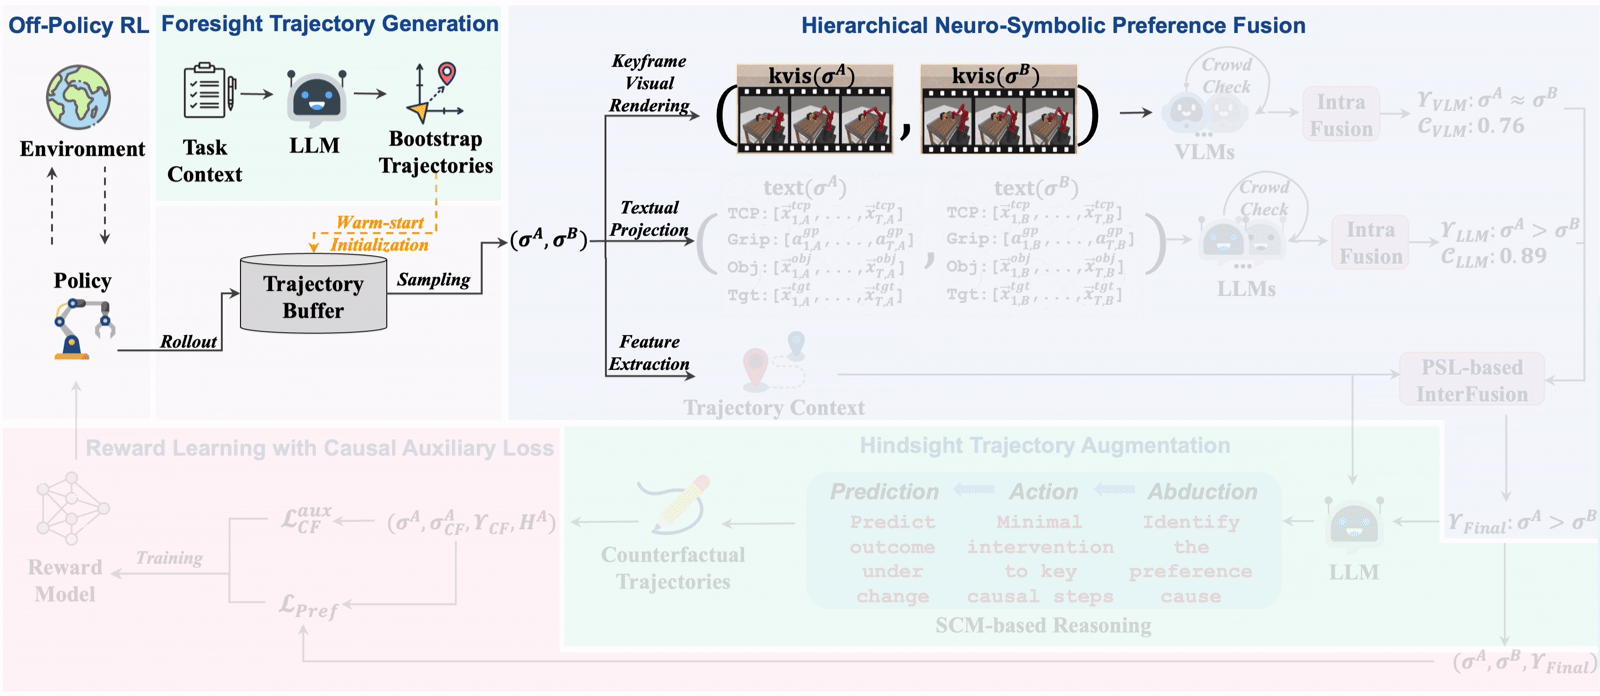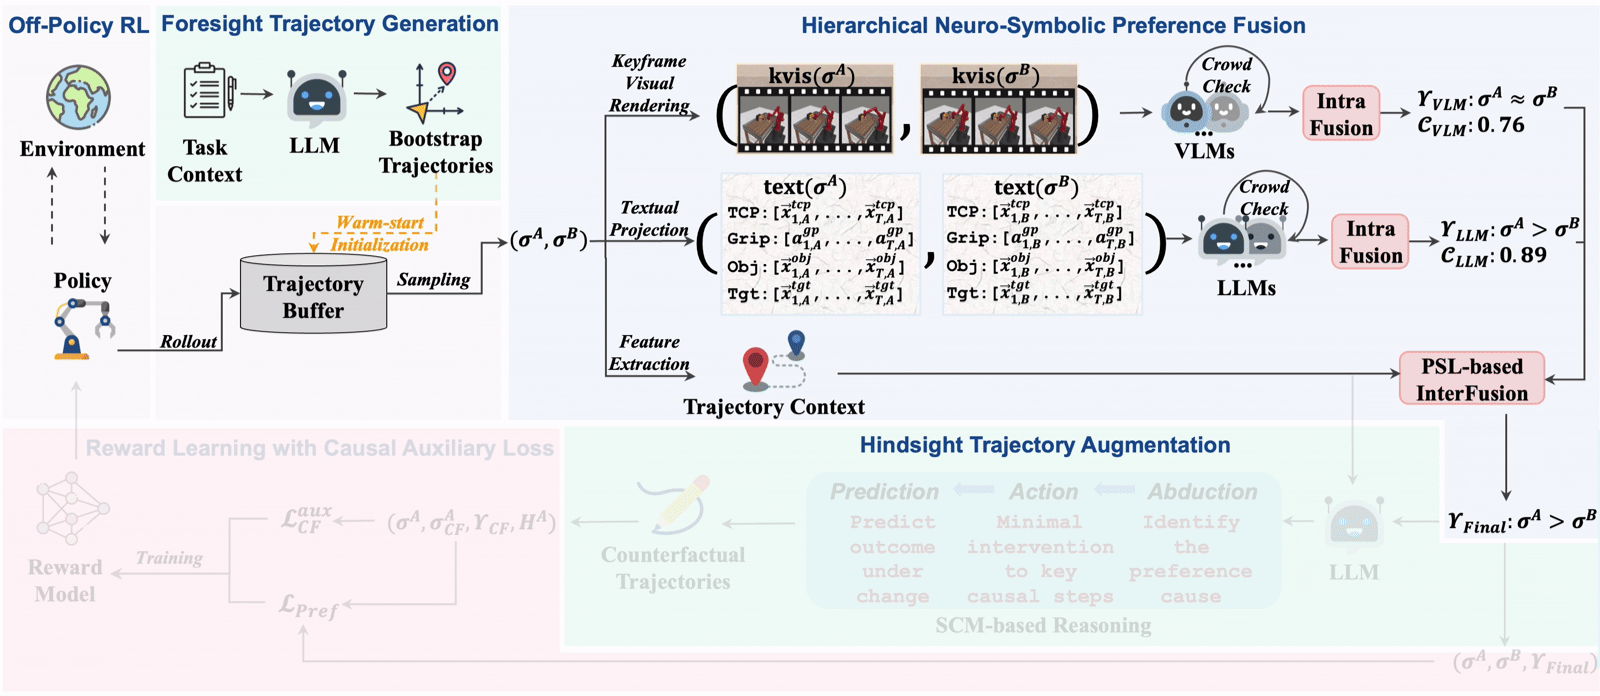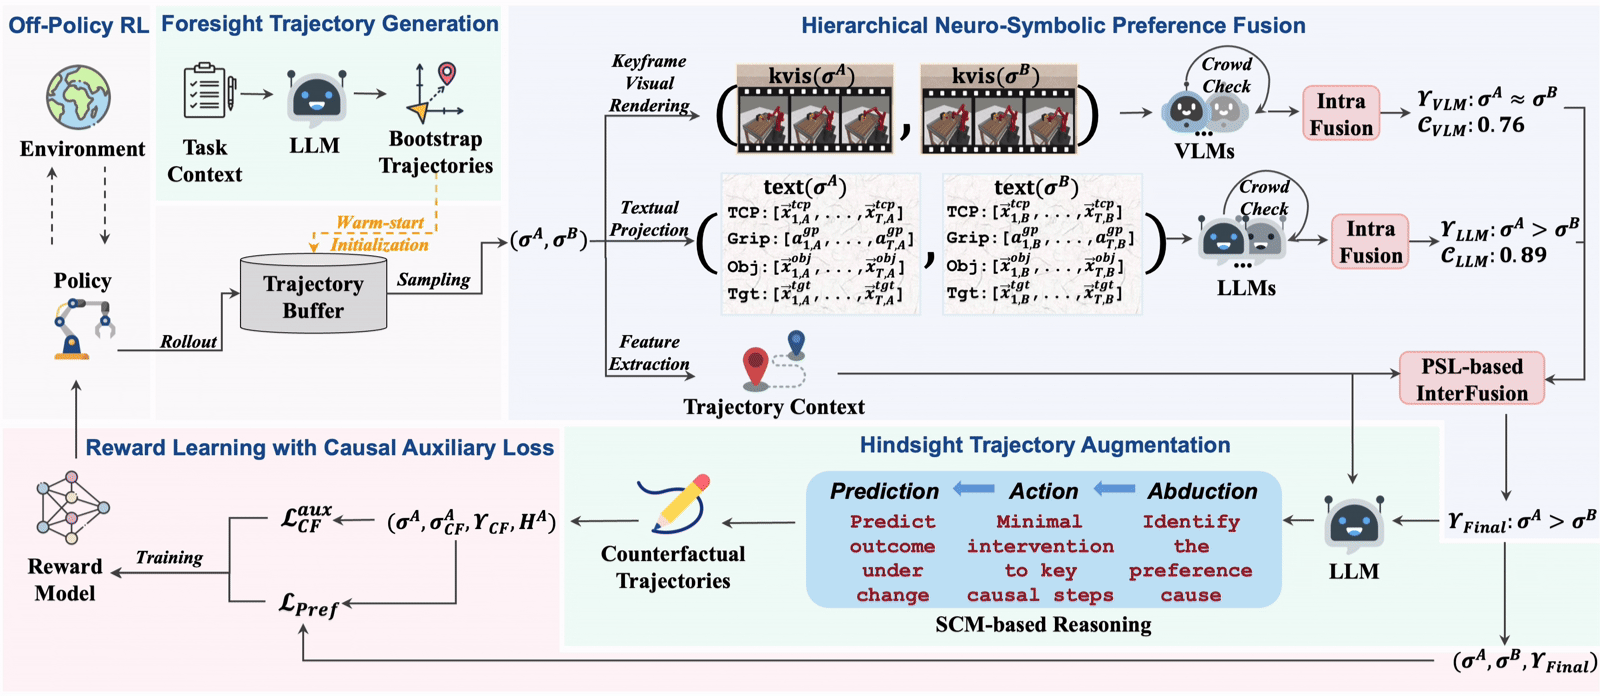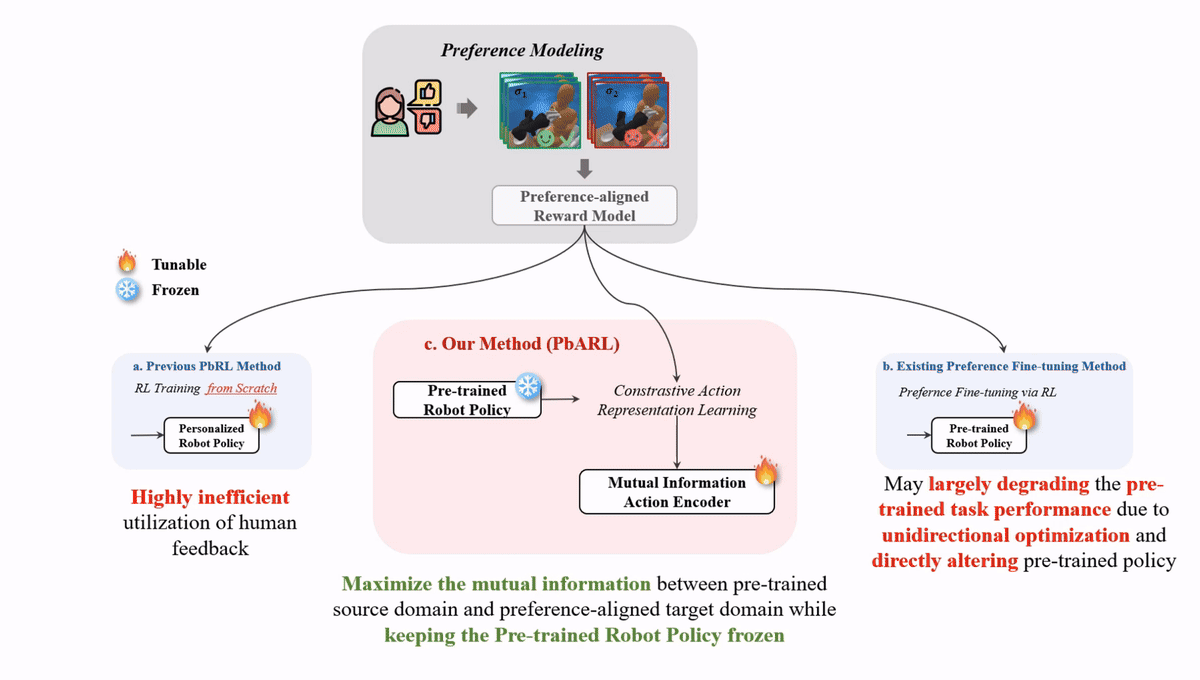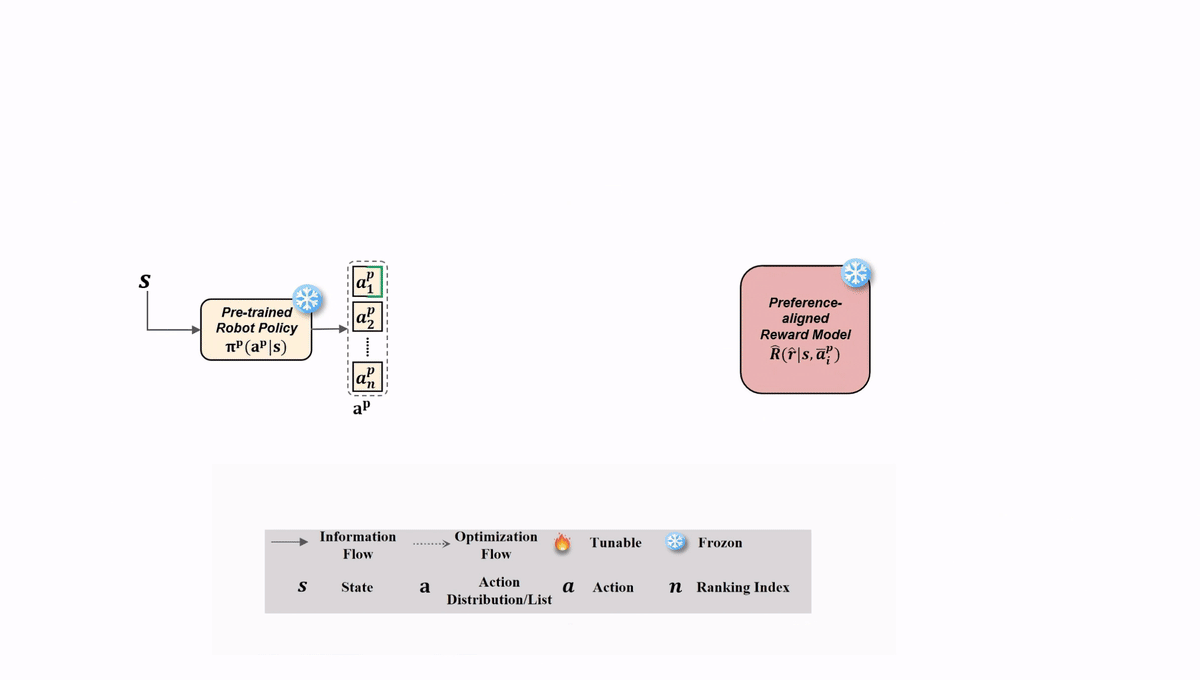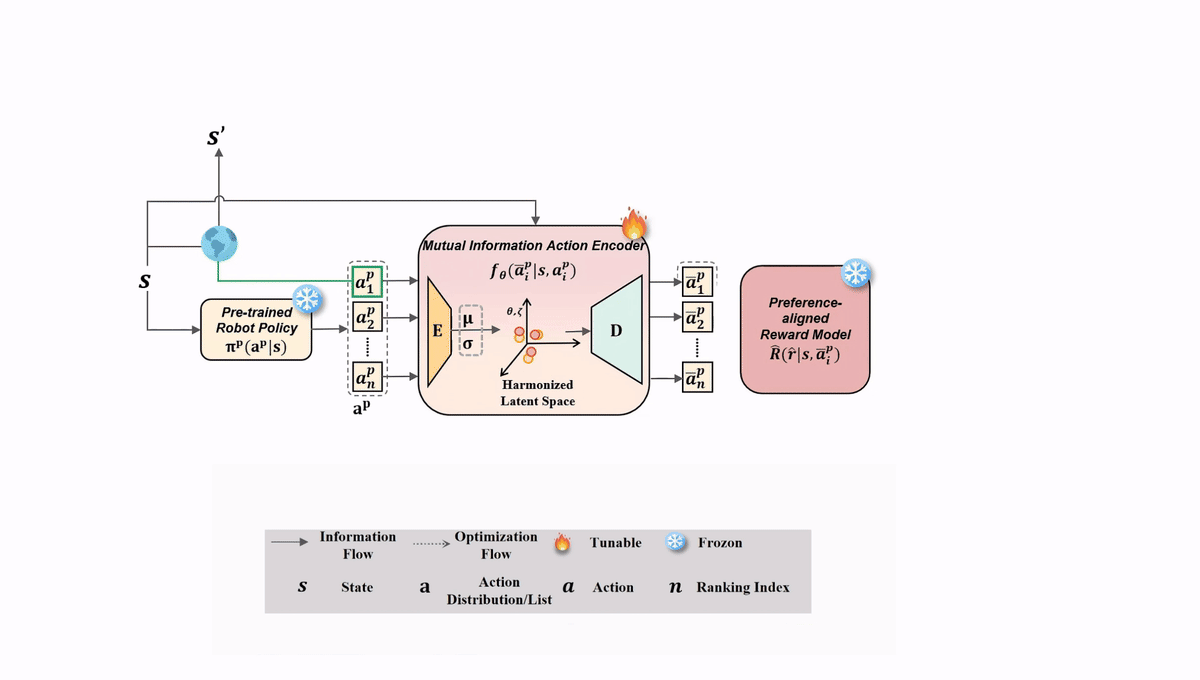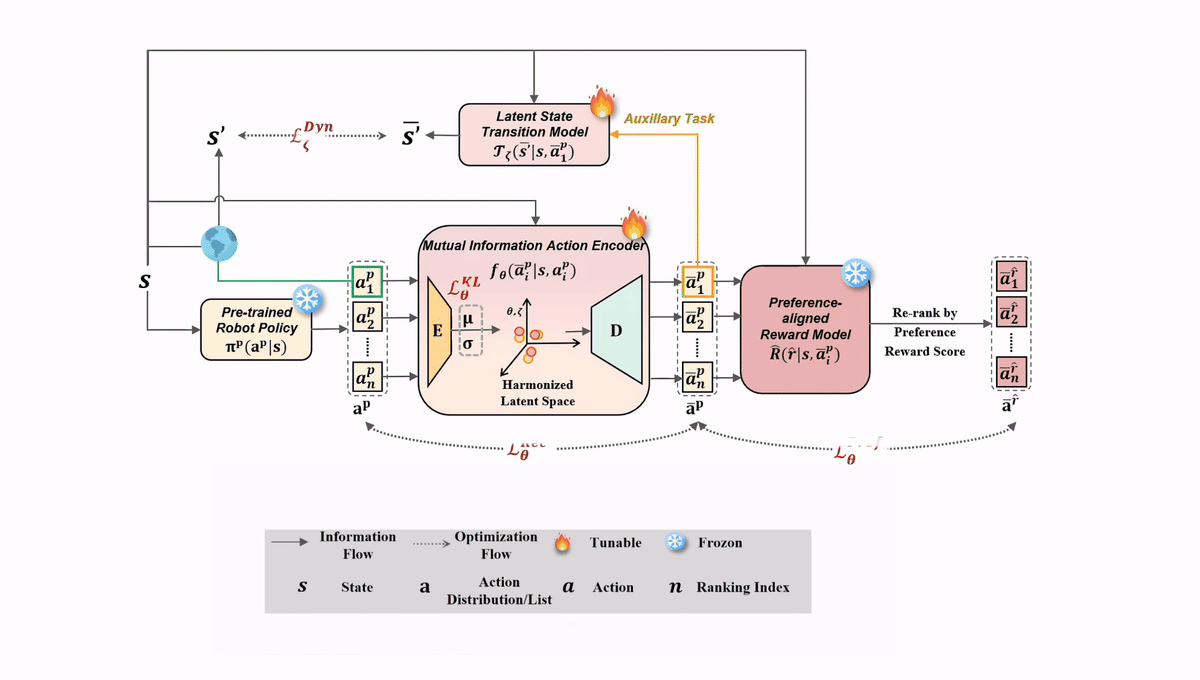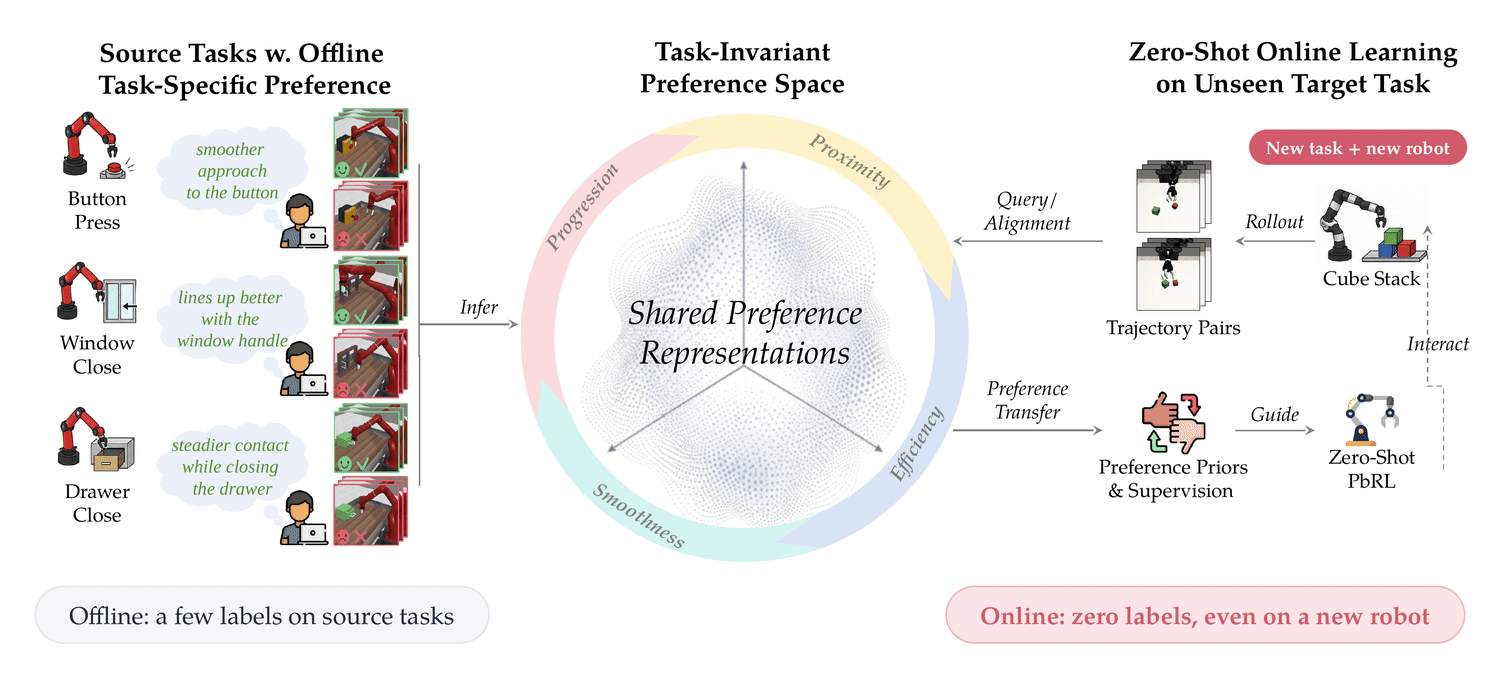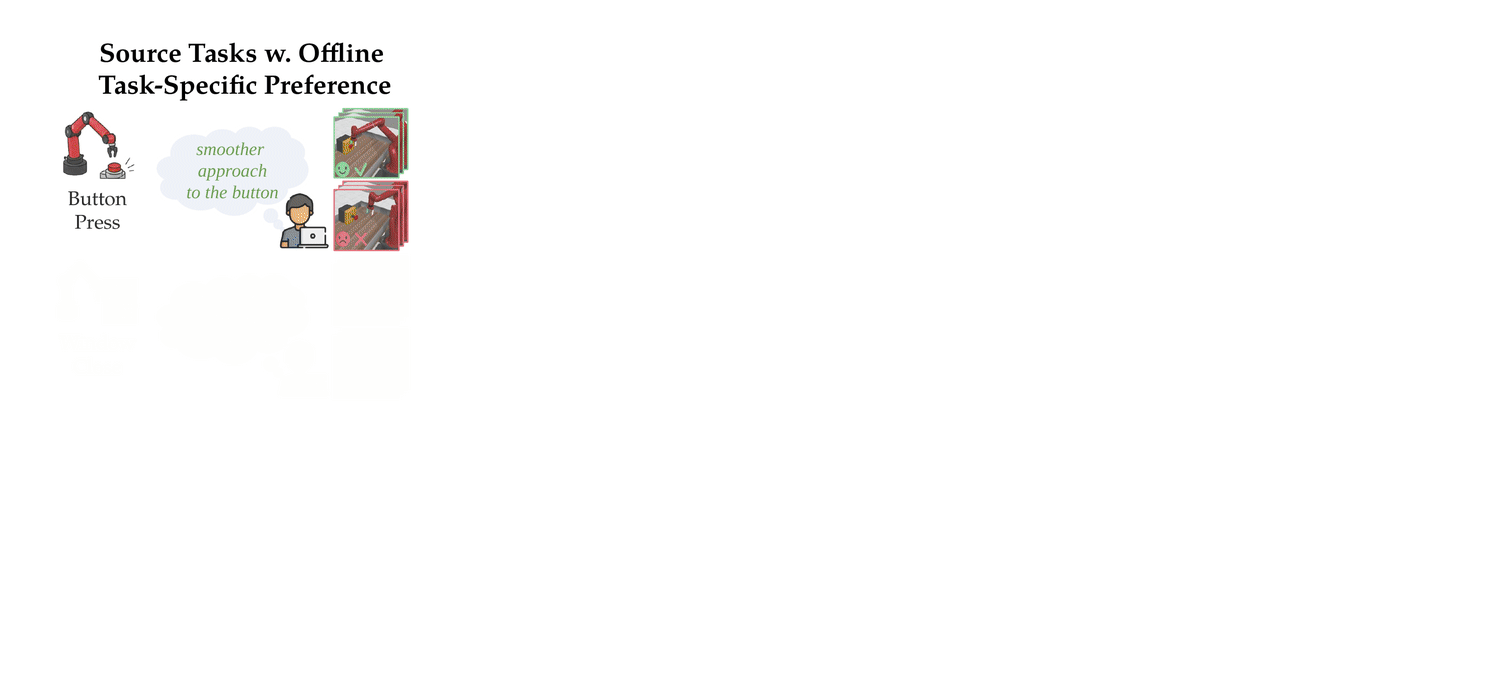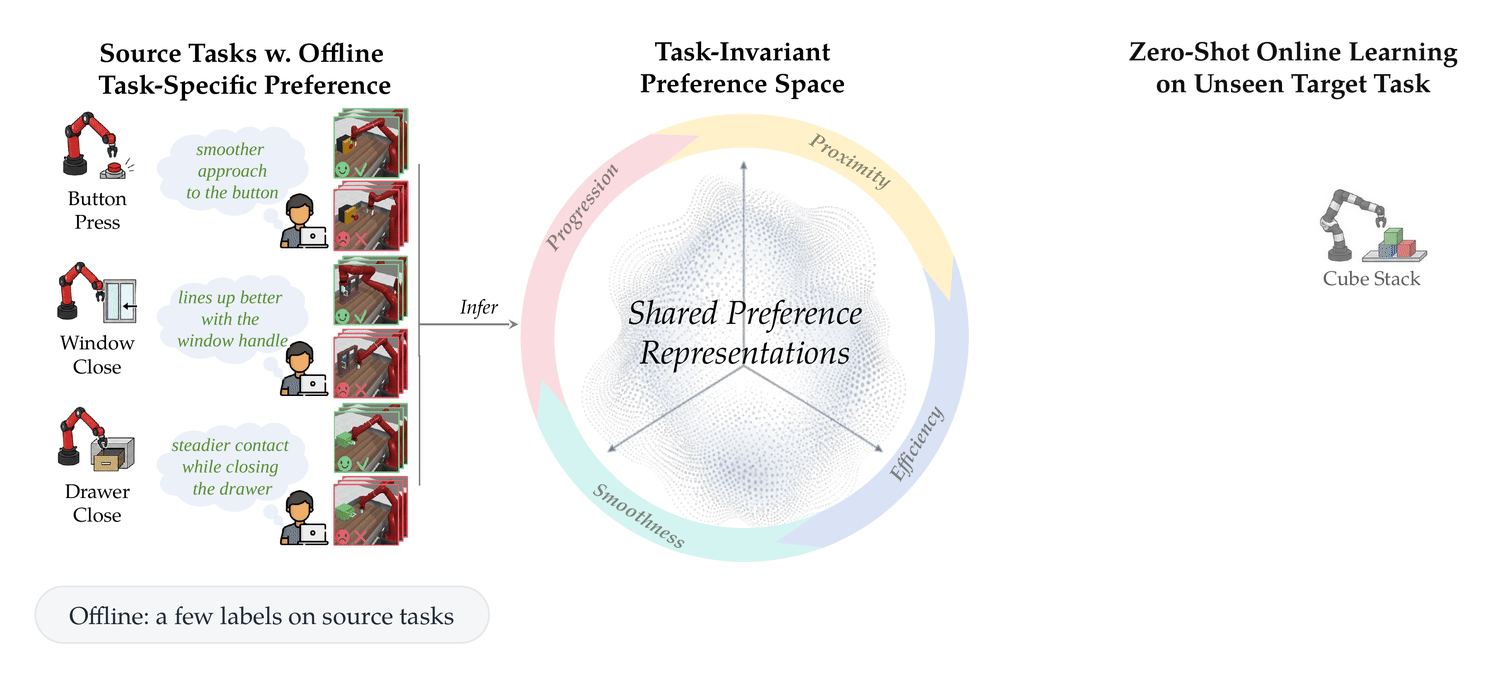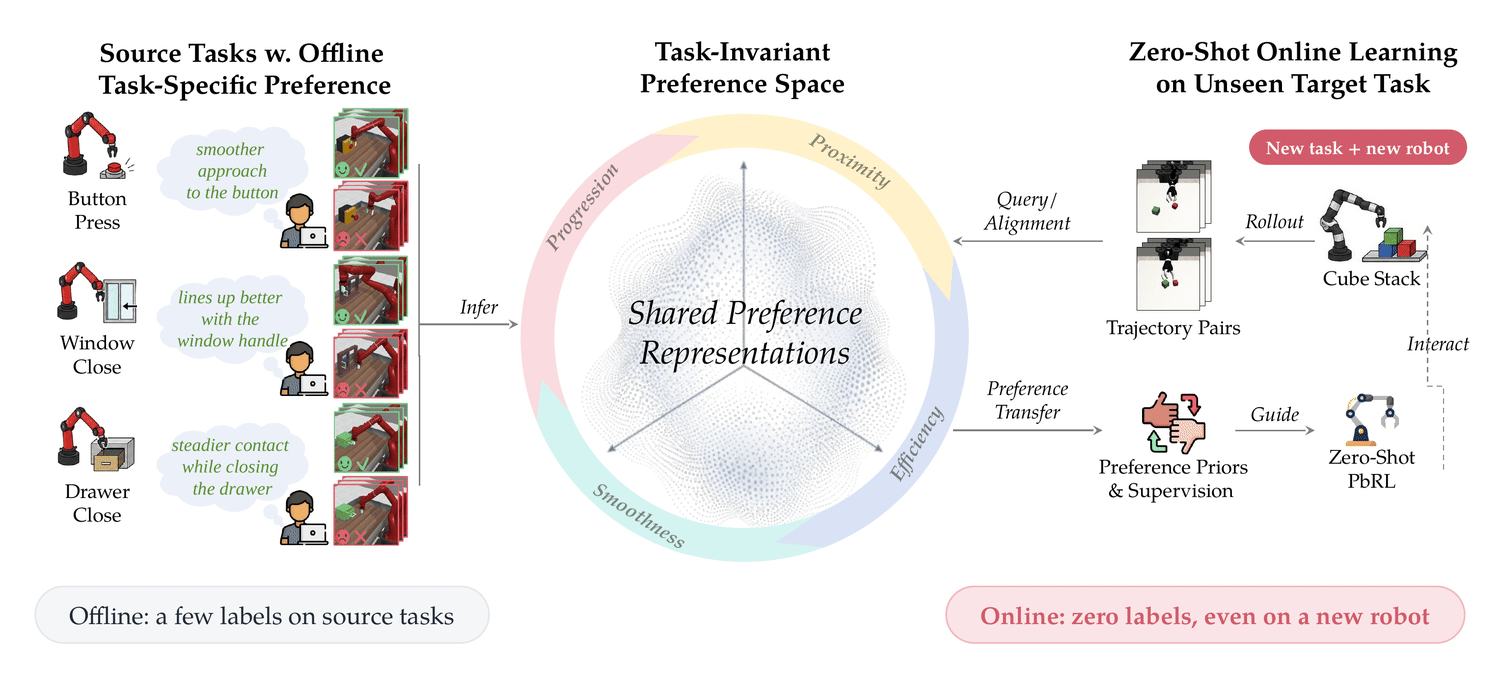
PrefO2O: Zero-Shot Preference-Based Reinforcement Learning via Offline-to-Online Latent Preference Transfer
HEAI Workshop, IROS 2026 Best Paper Award
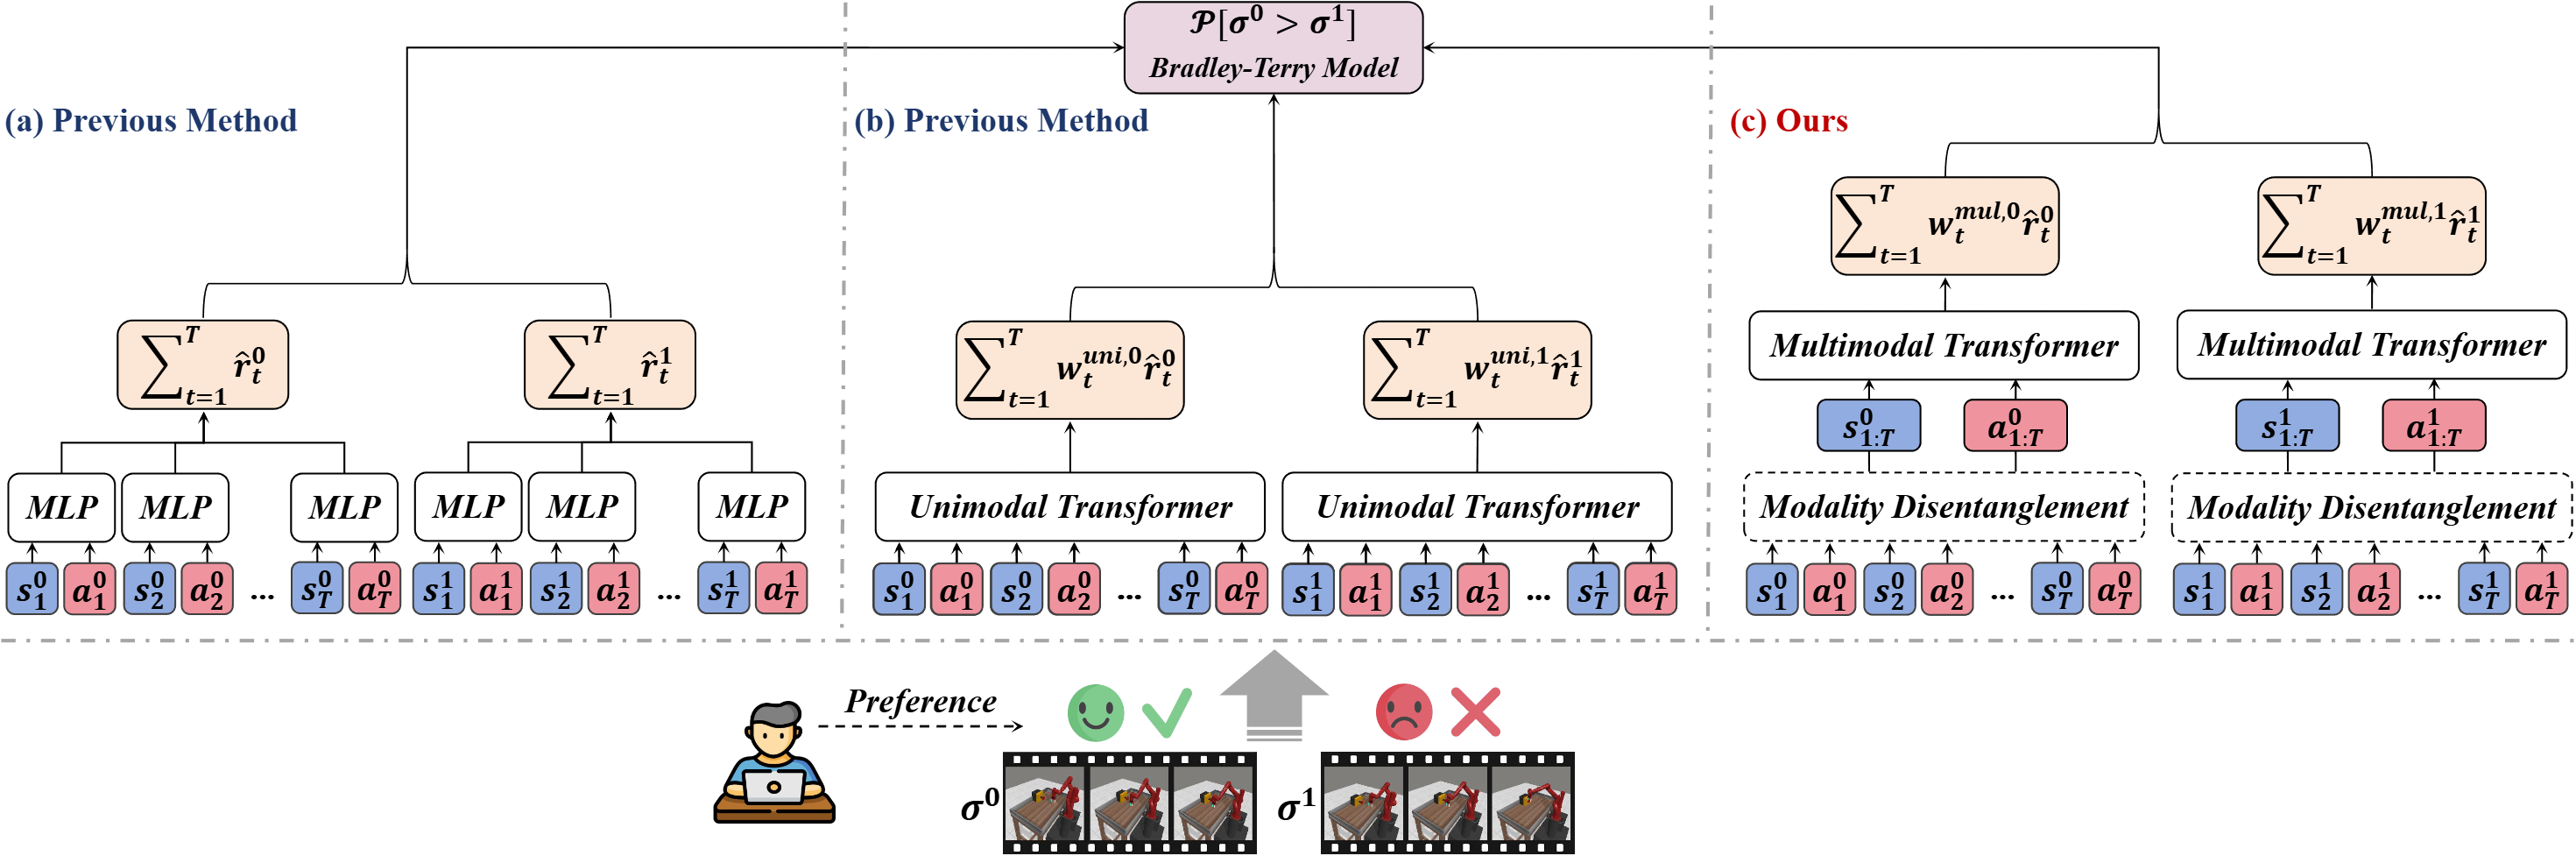
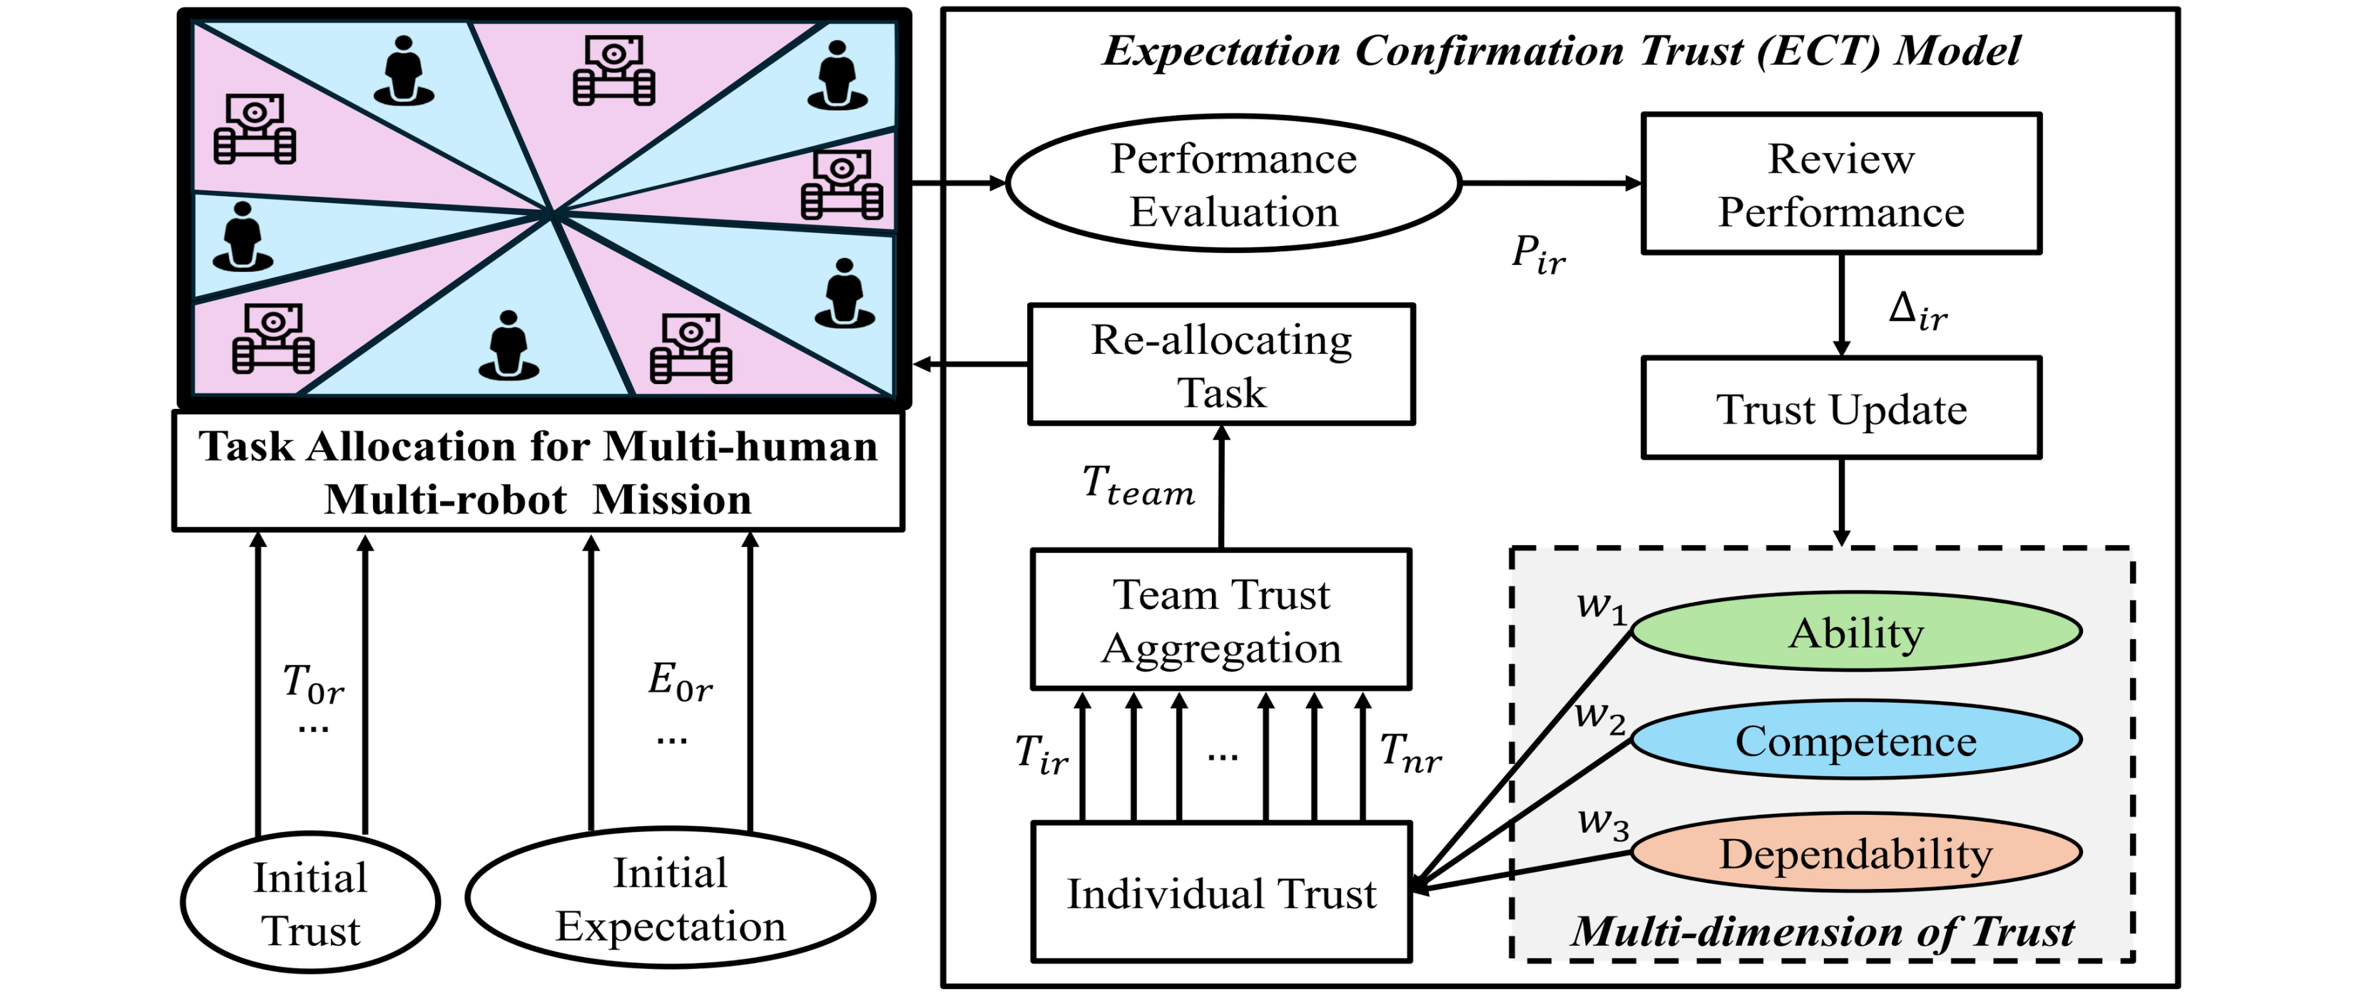
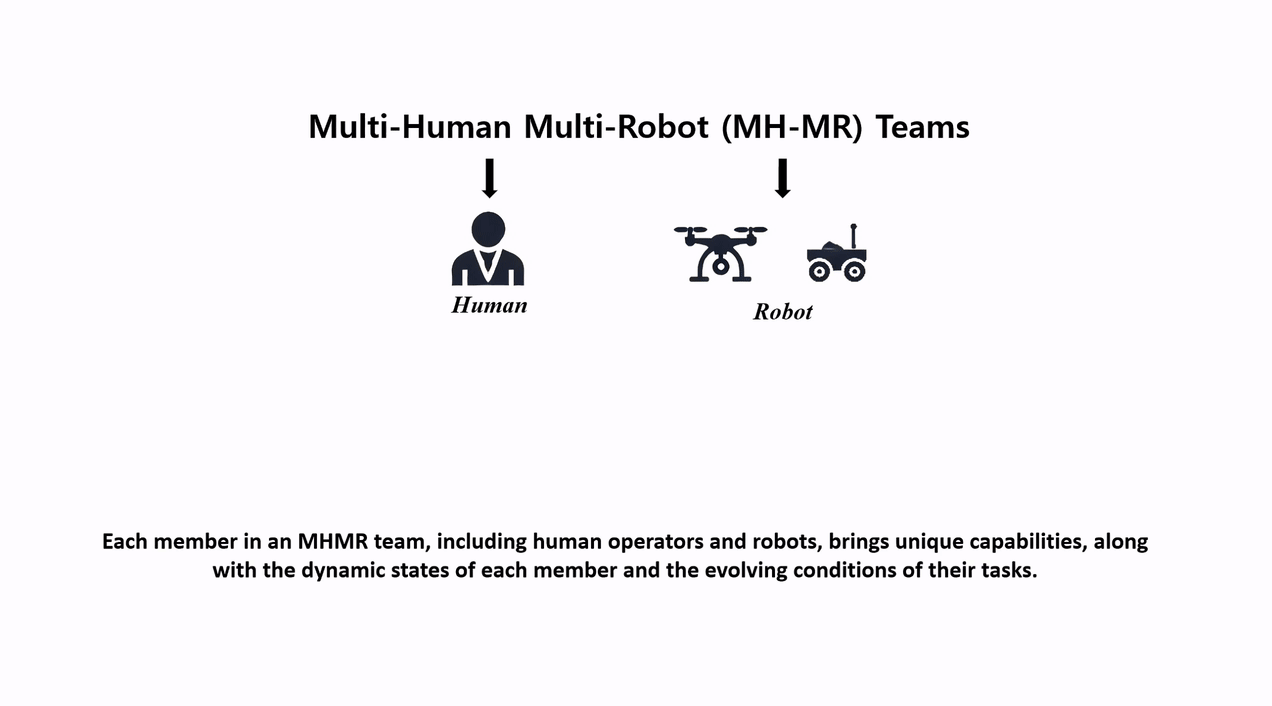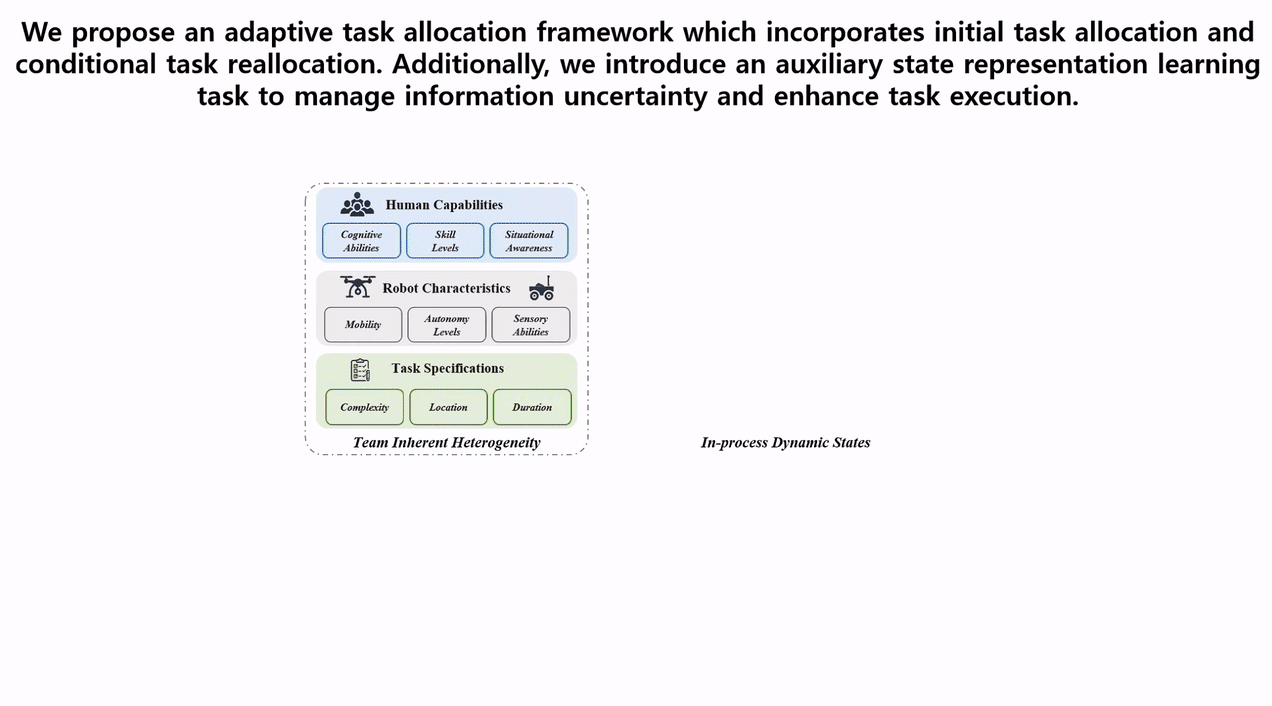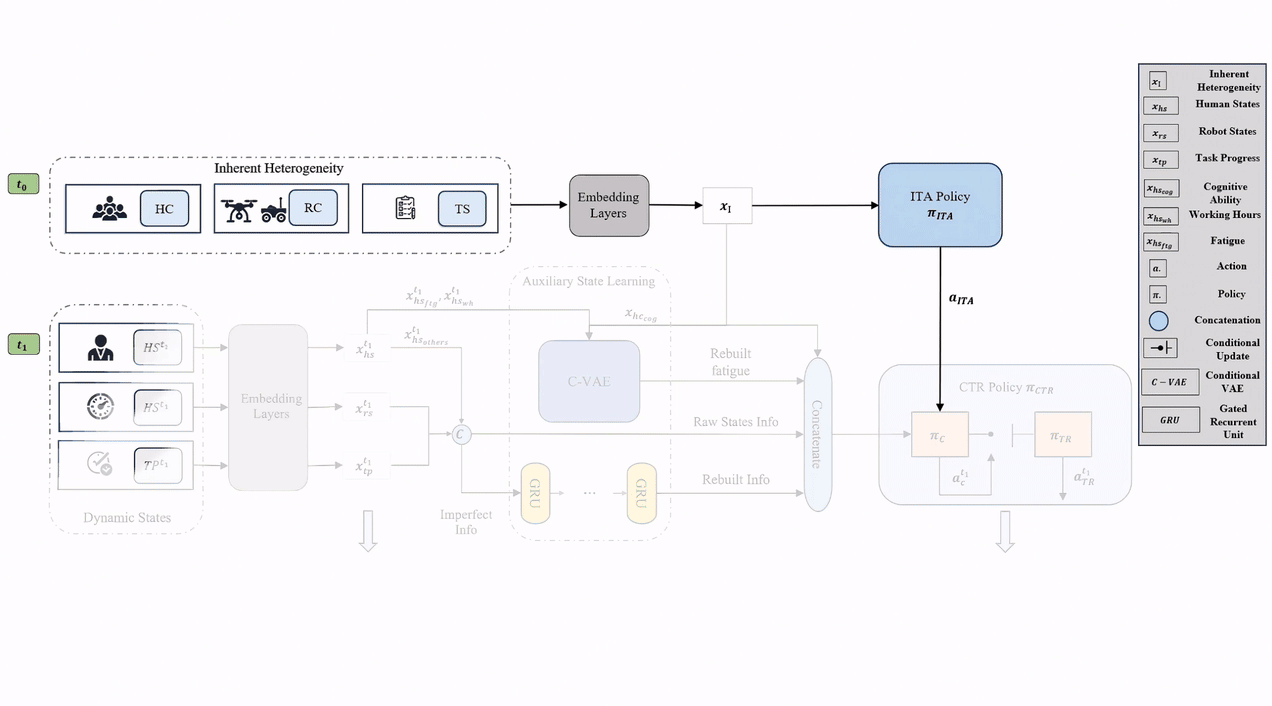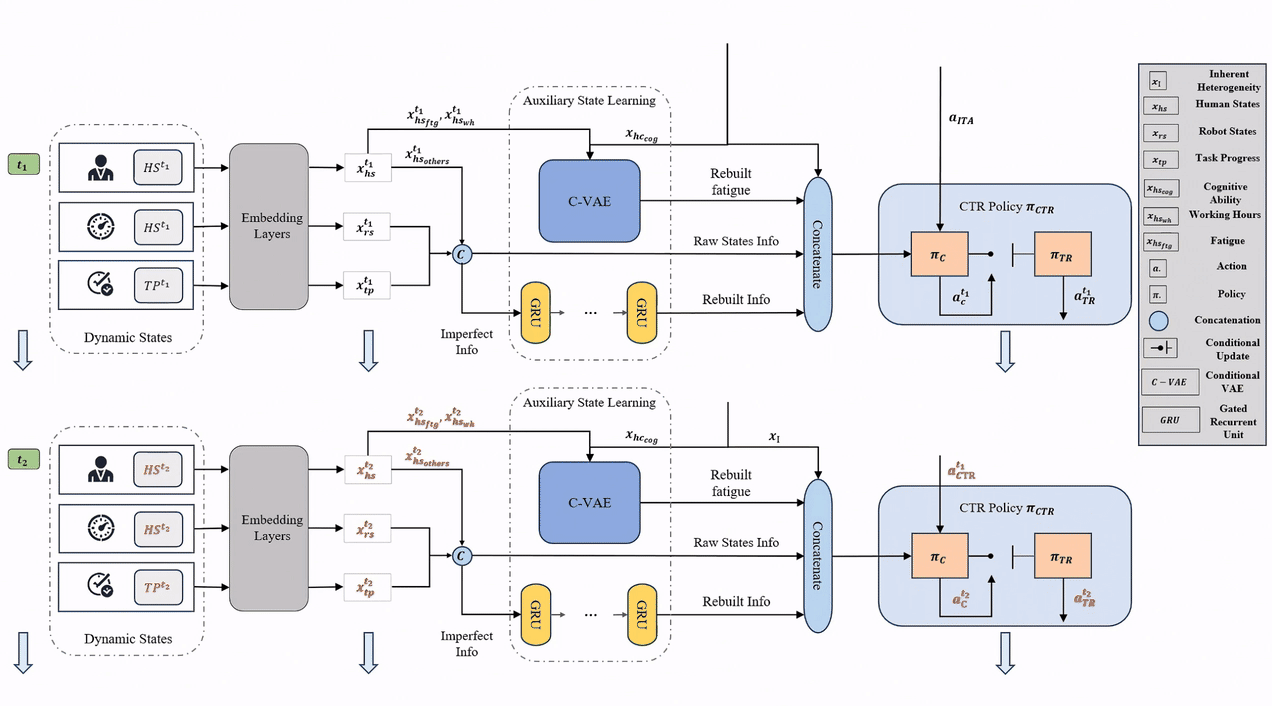
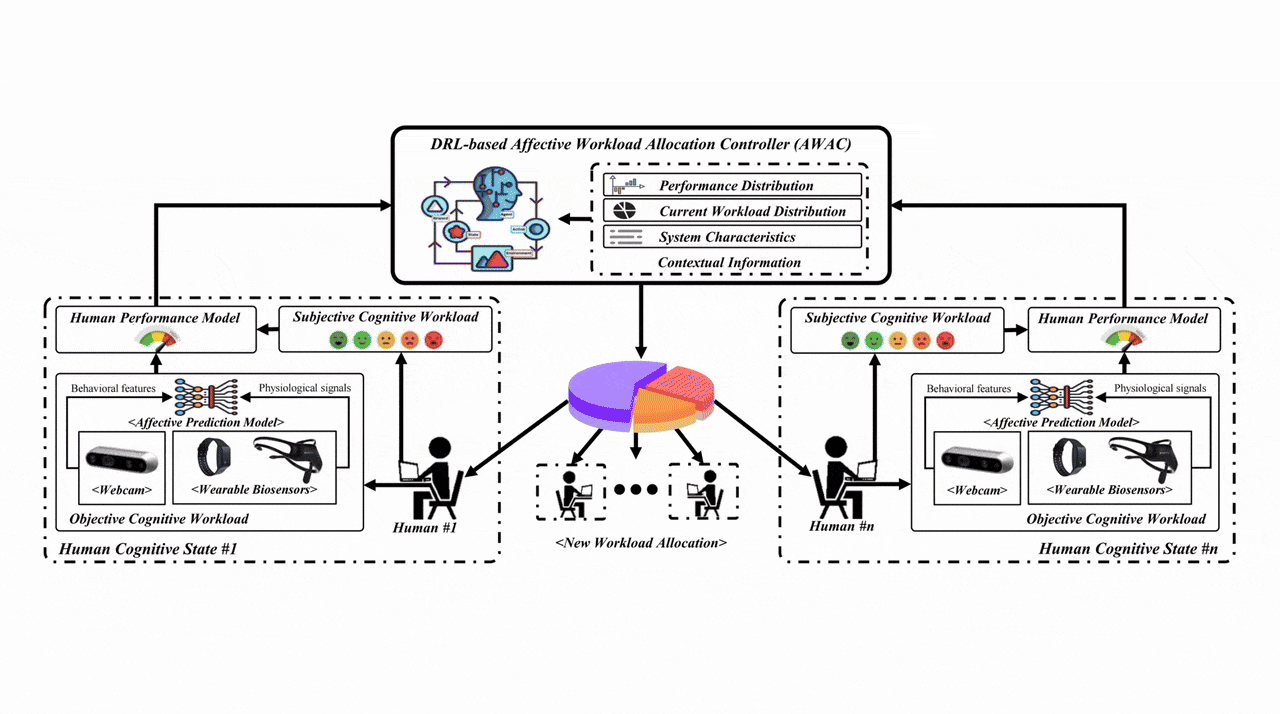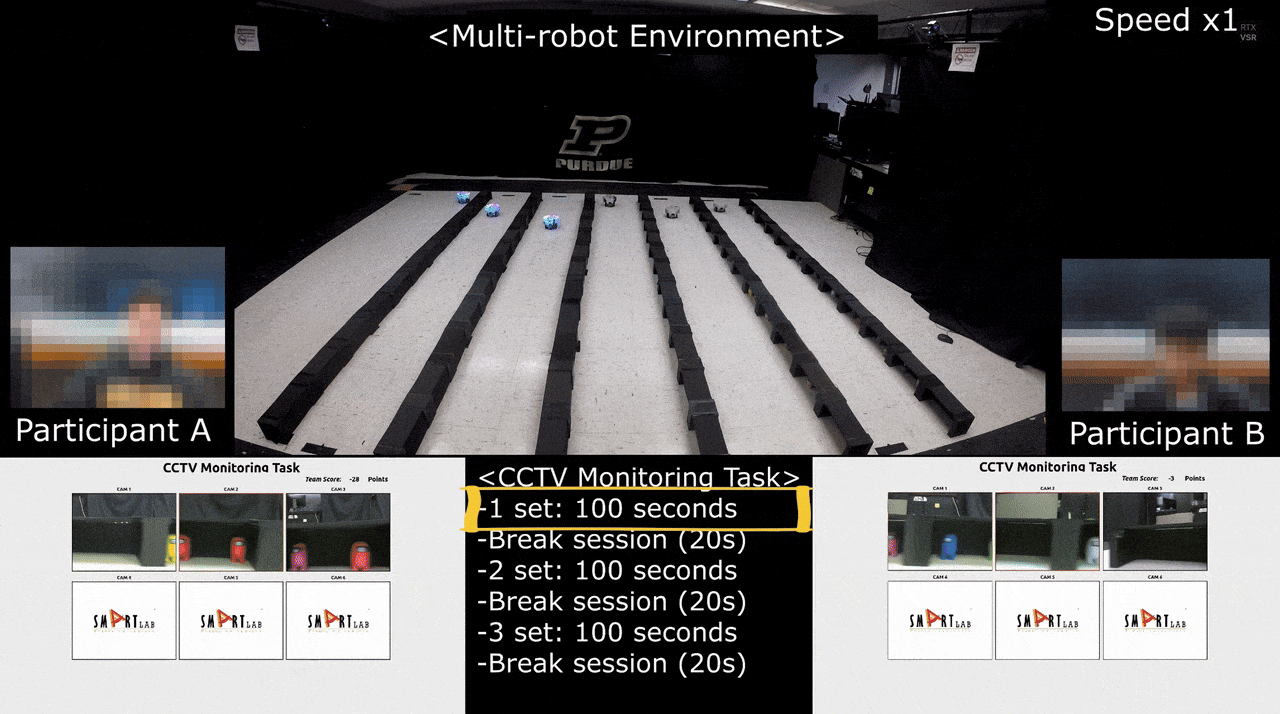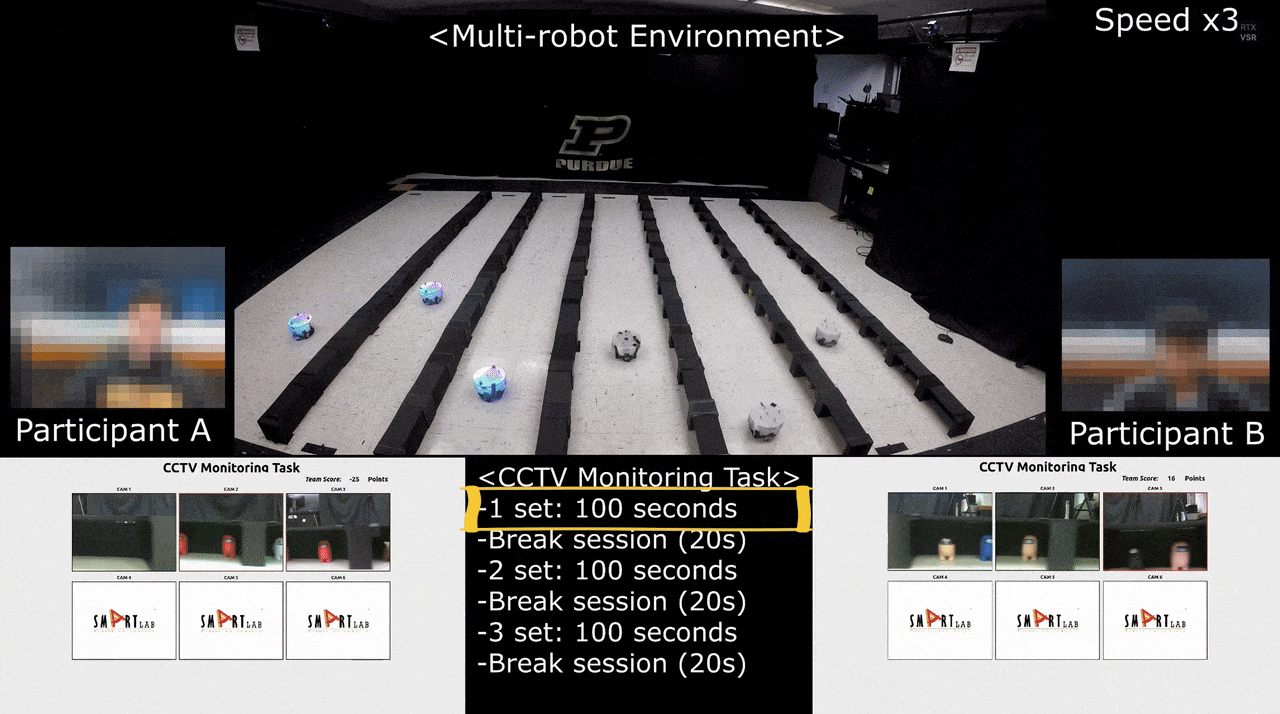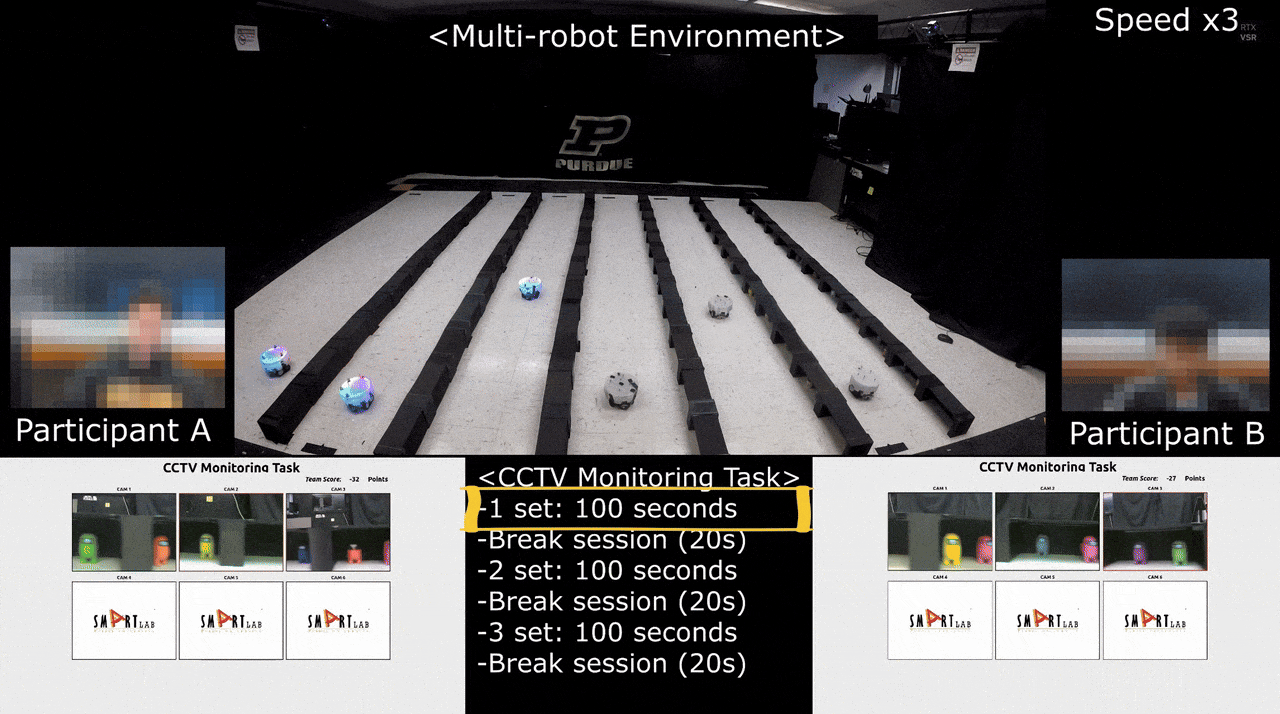
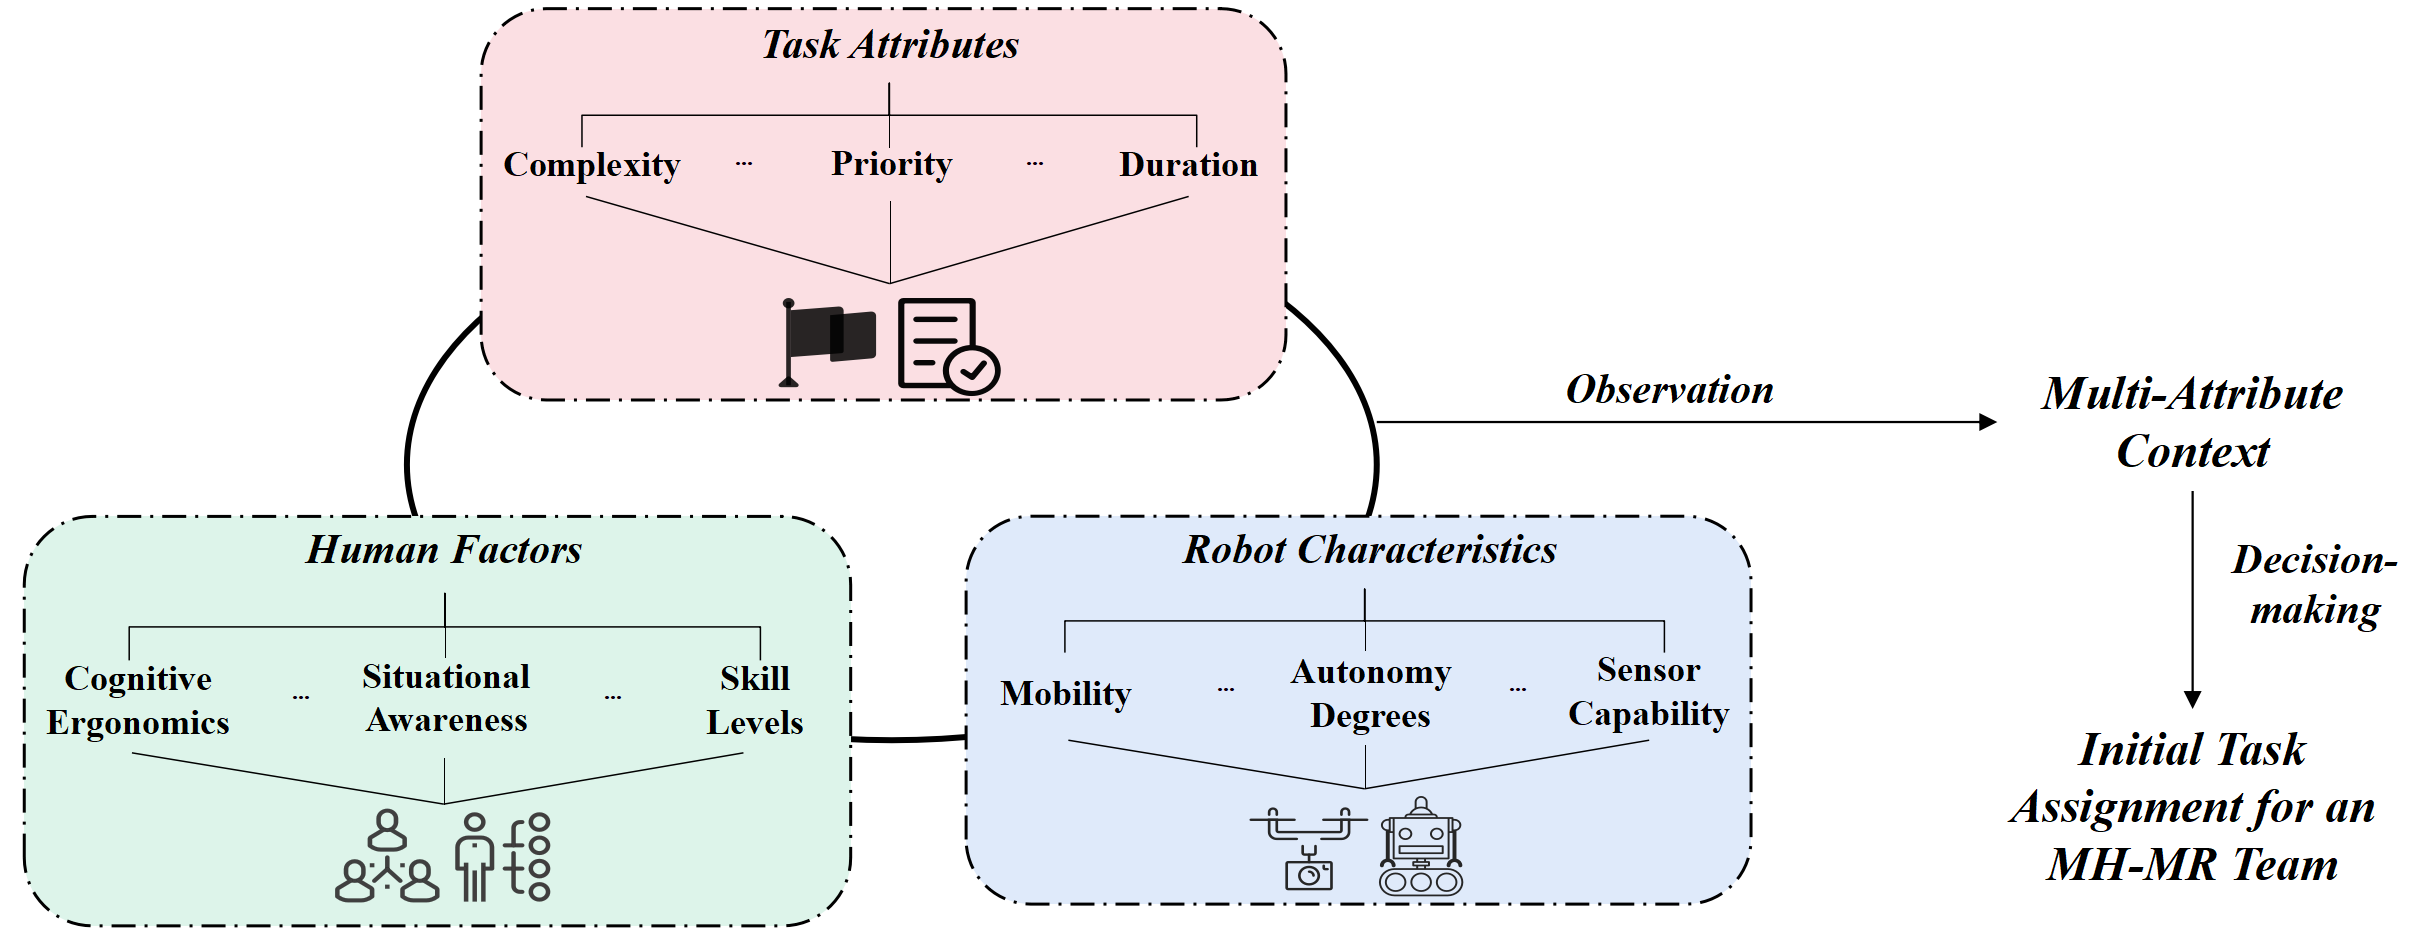
My research centers on robot learning from human feedback, enabling robots to generalize to new tasks and adapt to individual users. Alongside this core line, I have studied how robots perceive and adapt to broader human signals, such as cognitive workload and physiological state, and how these ideas extend to multi-human multi-robot teams.
Reverse chronological order. † Equal contribution · § Work I mentored · Also on Google Scholar.
HEAI Workshop, IROS 2026 Best Paper Award